Blog
// Lekker's Blog
Robot Hardware OEM Sourcing: An Asia Buyer Checklist
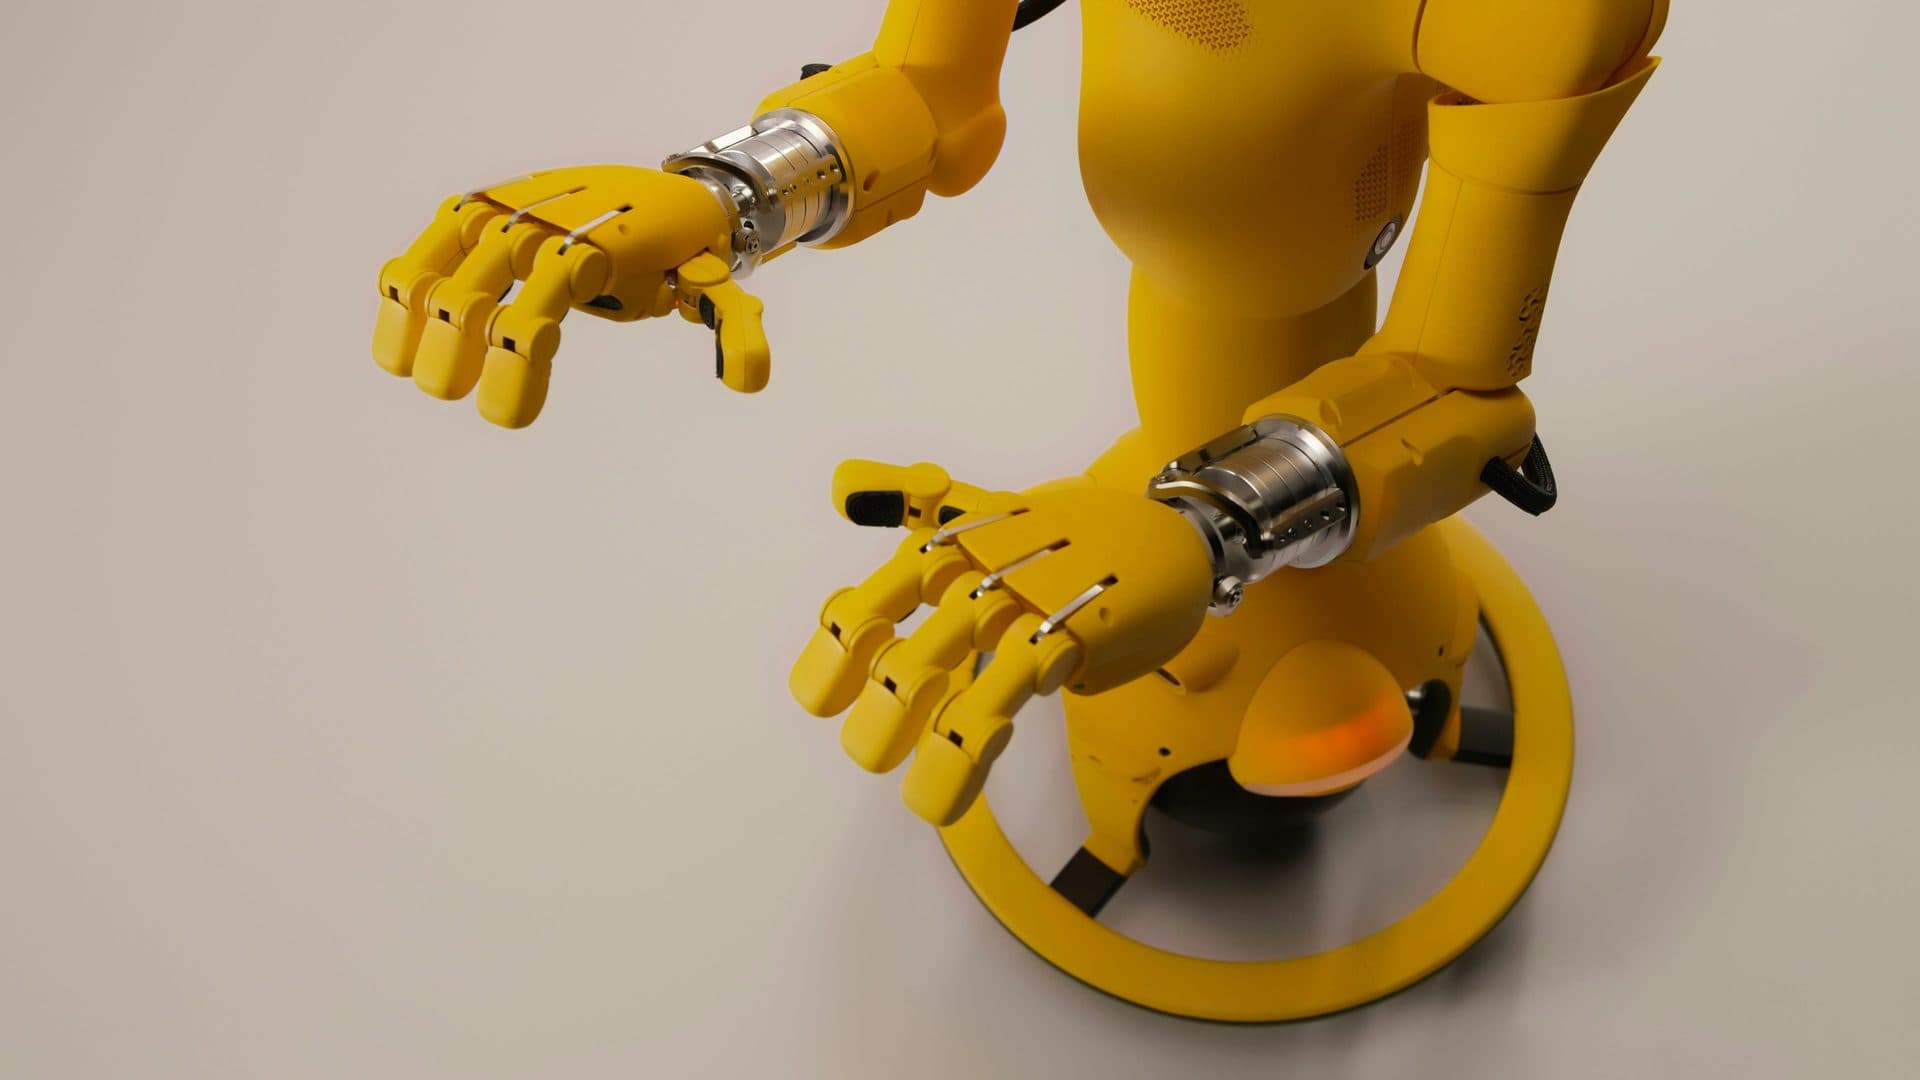
Robot hardware OEM sourcing in Asia is not a full robot from a catalogue, and it is not electronics or software. For industrial robot builders, integrators, and machine OEMs, it is metal hardware: bases and frames, covers, end-of-arm tooling plates, brackets, shafts, gear or motor housings, and other CNC or fabricated parts that must stay interchangeable lot to lot.
This checklist is for procurement and SQE teams who already have drawings and need a practical Asia qualify path. There is no Vietnam “robot factory” landscape post on this site — do not invent one. Award on process, metrology, and tooling ownership. If the geometry might still be cast, fabbed, or machined from solid, settle that with casting vs fabrication vs CNC sourcing. Then use find, qualify, and factory audit. Tight machining sits next to CNC tolerances when sourcing in Vietnam as proof that Asia CNC can be serious — not as a blanket robot-hardware award.
Five gates:
1. Name the hardware family on the RFQ
Robot programs fail when the RFQ says “robot parts” and every plant guesses a different cell.
Split structural (welded frames, bases, covers) from precision (housings, shafts, EOAT plates, datum blocks)
Drawing revision, material, heat treat, and finish — including which state is inspected
Datums that match how the part locates on the robot or cell, not a convenient mill setup
Hardware, dowels, and threaded inserts that must match spare-part interchangeability
Cleanliness, marking, and packing so machined faces and tapped holes survive export
Volume band and spare/service demand — robot hardware often lives longer than the first build lot
Send the same pack to every bidder. A plant quoting a weldment as if it were a tight housing, or a CNC shop quoting a large frame it cannot fixture, is not a cost comparison. If two plants assume different process routes, stop and lock the route before you chase price.
2. Match process and cell to the part — not to “automation”
Not every Asia metal plant is a robot-hardware plant.
Frames and covers: laser / brake / weld, fixture strategy, distortion control
Housings and plates: mill/turn envelope, fixture stiffness, in-process probing
Cast or forged blanks only when the foundry/forge route is named and machined in a controlled second step
Heat treat and grind when hardness or geometry move after quench — write who owns that hop
Max size and mass the plant actually runs, verified on the floor, not from a brochure robot photo
A shop that makes generic brackets may still fail an EOAT plate that must locate to a few hundredths after finish. Score the constraint: weld distortion on a base, true position on a housing, or surface that a seal or bearing needs. Do not shortlist on “we supply automotive” or “we have seen robots in the aisle.”
3. Repeatability, metrology, and spare interchangeability
Robot hardware fails quietly when lot two does not bolt up like lot one.
Lock CMM / gauge points to assembly datums — same program for FAI and incoming
Production-intent sample from the intended machine class and fixture, not a prototype cell
Compare FAI to drawing and to any legacy EU/Japan/China part on the same points
Write which balloons are CTQ for motion, sealing, or payload vs which are general
Spare-part rule: a field replacement must fit without hand-fit; if it cannot, the process is not locked
Treat capability talk as questions, not brochure microns. Ask what they hold on your envelope and material. If the plant cannot show metrology and a fixture approach, you do not have robot-hardware supply — you have a sample.
4. Finish, cleanliness, and secondaries
Motion hardware is incomplete at the mill.
Map in-house vs outsourced plate, anodize, paint, heat treat, and grind
Deburr and chip rules on tapped holes, ports, and mating faces
Cleanliness or residual-oil expectations if the part goes into a sealed or high-cycle joint
Traceability of heat and finish lots for claims months later
Packing that protects datums and coatings — robot covers scratch; housings ding on parting lines
A strong CNC cell with anonymous plating is an incomplete robot-hardware source. Write which secondaries you will audit. Keep CTQs off “we will try” finish language.
5. Tooling, IP of process, and volume gates
Close before the first production PO:
Who owns fixtures, CMM programs, and nest/CAM — and can they transfer (tooling ownership)
Dual-source rule if the robot program cannot stop for one plant’s queue
FAI then a pilot that stresses the constraint process (weld + machine, or machine + plate), not only a pretty cover
SQE scorecard: process fit, QC independence, delivery, ECN turnaround
Change control: who gets the next revision first so field spares stay interchangeable
When on-site verification must run through FAI and lot release, OEM & Component Sourcing keeps robot hardware tied to shop-floor proof — not a cheaper line that will not bolt on in the field.
Robot hardware OEM sourcing in Asia works when you name the metal family, match process to the constraint, lock metrology and spares, map finish hops, and stage volume on owned fixtures. Skip a gate and you have bought a sample that looked like a robot part, not a transferable OEM source.